Algorithms
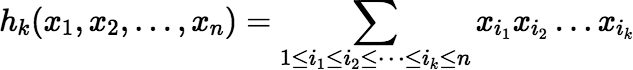
|
(1) | |
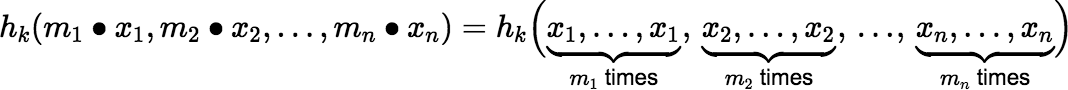
|
(2) |
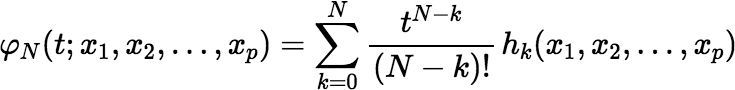
|
(3) |
1. Incremental calculation of hk(x1, x2, …, xn), for increasing k, with O(n) increment step
| 1 | for i = 1 to n loop | |||
| 2 | wi ← 1 | // wi = h0(x1, x2, …, xi) = 1 | ||
| 3 | end loop | |||
| 4 | for k = 1 to … loop | |||
| 5 | w1 ← x1 w1 | // w1 = hk(x1) = x1k | ||
| 6 | for i = 2 to n loop | |||
| 7 | wi ← wi − 1 + xi wi | // wi = hk(x1, x2, …, xi) | ||
| 8 | end loop | |||
| 9 | output wn | // wn = hk(x1, x2, …, xn) | ||
| 10 | end loop | |||
2. Incremental calculation of hk(m1 • x1, m2 • x2, …, mn • xn) — which may be useful when ∑ mi ≫ n
| 1 | y ← 1 | // y = h0(m1 • x1, …, mn • xn) | ||
| 2 | for i = 1 to n loop | |||
| 3 | wi ← 0 | |||
| 4 | end loop | |||
| 5 | for k = 1 to … loop | |||
| 6 | s ← 0 | |||
| 7 | for i = 1 to n loop | // O(n) loop | ||
| 8 | wi ← xi (wi + mi y) | |||
| 9 | s ← s + wi | |||
| 10 | end loop | |||
| 11 | y ← s / k | // y = hk(m1 • x1, …, mn • xn) | ||
| 12 | output y | |||
| 13 | end loop | |||
The same algorithm may be useful when the mi are not integers (e.g., when calculating a convolution of gamma distributions with varying scale parameters). In this case the algorithm outputs for each k the value:
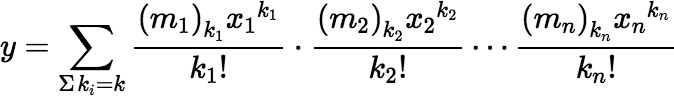
3. Incremental calculation of φk(t; x1, x2, …, xn)
| 1 | for i = 0 to n loop | |||
| 2 | wi ← 1 | // wi = φ0(t; x1, x2, …, xi) = 1 | ||
| 3 | end loop | |||
| 4 | for k = 1 to … loop | |||
| 5 | w0 ← w0 t / k | // w0 = φk(t; ~) = t k / k! | ||
| 6 | for i = 1 to n loop | // O(n) loop | ||
| 7 | wi ← wi − 1 + xi wi | // wi = φk(t; x1, x2, …, xi) | ||
| 8 | end loop | |||
| 9 | output wn | // wn = φk(t; x1, x2, …, xn) | ||
| 10 | end loop | |||
4. If G(s) is the rational function:
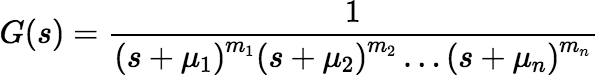
then the inverse Laplace transform of G(s) is the function:
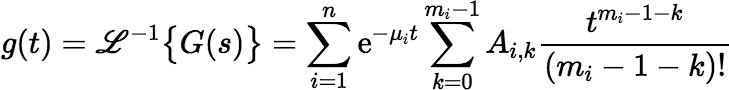
where Ai, k is given by:
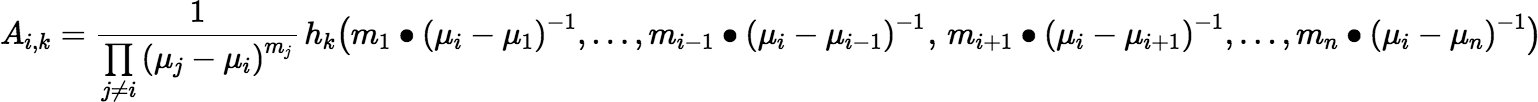
If one modifies G(s) by incrementing mj for some 1 ≤ j ≤ n, then g(t) is replaced by (g ∗ Dμj)(t), and the coefficients Ai, k change as shown below:
| 1 | s ← 0 | ||||
| 2 | for i = 1 to n loop | ||||
| 3 | if i ≠ j then | ||||
| 4 | Ai, 0 ← Ai, 0 / (μj − μi) | ||||
| 5 | for k = 1 to mi − 1 loop | ||||
| 6 | Ai, k ← (Ai, k − Ai, k − 1) / (μj − μi) | ||||
| 7 | end loop | ||||
| 8 | s ← s + Ai, mi − 1 | ||||
| 9 | end if | ||||
| 10 | end loop | ||||
| 11 | Aj, mj ← −s | // new coefficient | |||
| 12 | mj ← mj + 1 | ||||
If j = n + 1 so that we are including a new factor (s + μn + 1) in the denominator of G(s), insert the line mj ← 0 before line 1 and append the line n ← n + 1 after line 12.
If the value of g(t) is needed only for a specific value of t, and if it is known that one mj will be incremented repeatedly and no other mi will increase, then a different version of the algorithm can be used to recalculate Ai, k only for i ≠ j, without accumulating the sum s. The sum of all the Aj, k terms can be recalculated at each iteration using the φ function above without calculating the individual coefficients Aj, k.
Note: Given any function g(t) of the form:
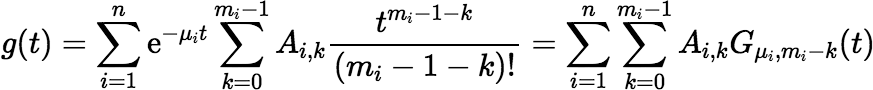
with arbitrary coefficients Ai, k, if we wish to calculate (g ∗ Dμj)(t), the same algorithm for updating the coefficients works. However, the shortcut method of evaluating g(t) using the φ function is not guaranteed to work for arbitrary Ai, k.